Planetary Robotics · Rocker-Bogie Suspension · Scientific Manipulation — 2024 — Present
LEAP-One Mars Analogue Rover
Planetary exploration rover engineered for rugged analogue sampling missions.
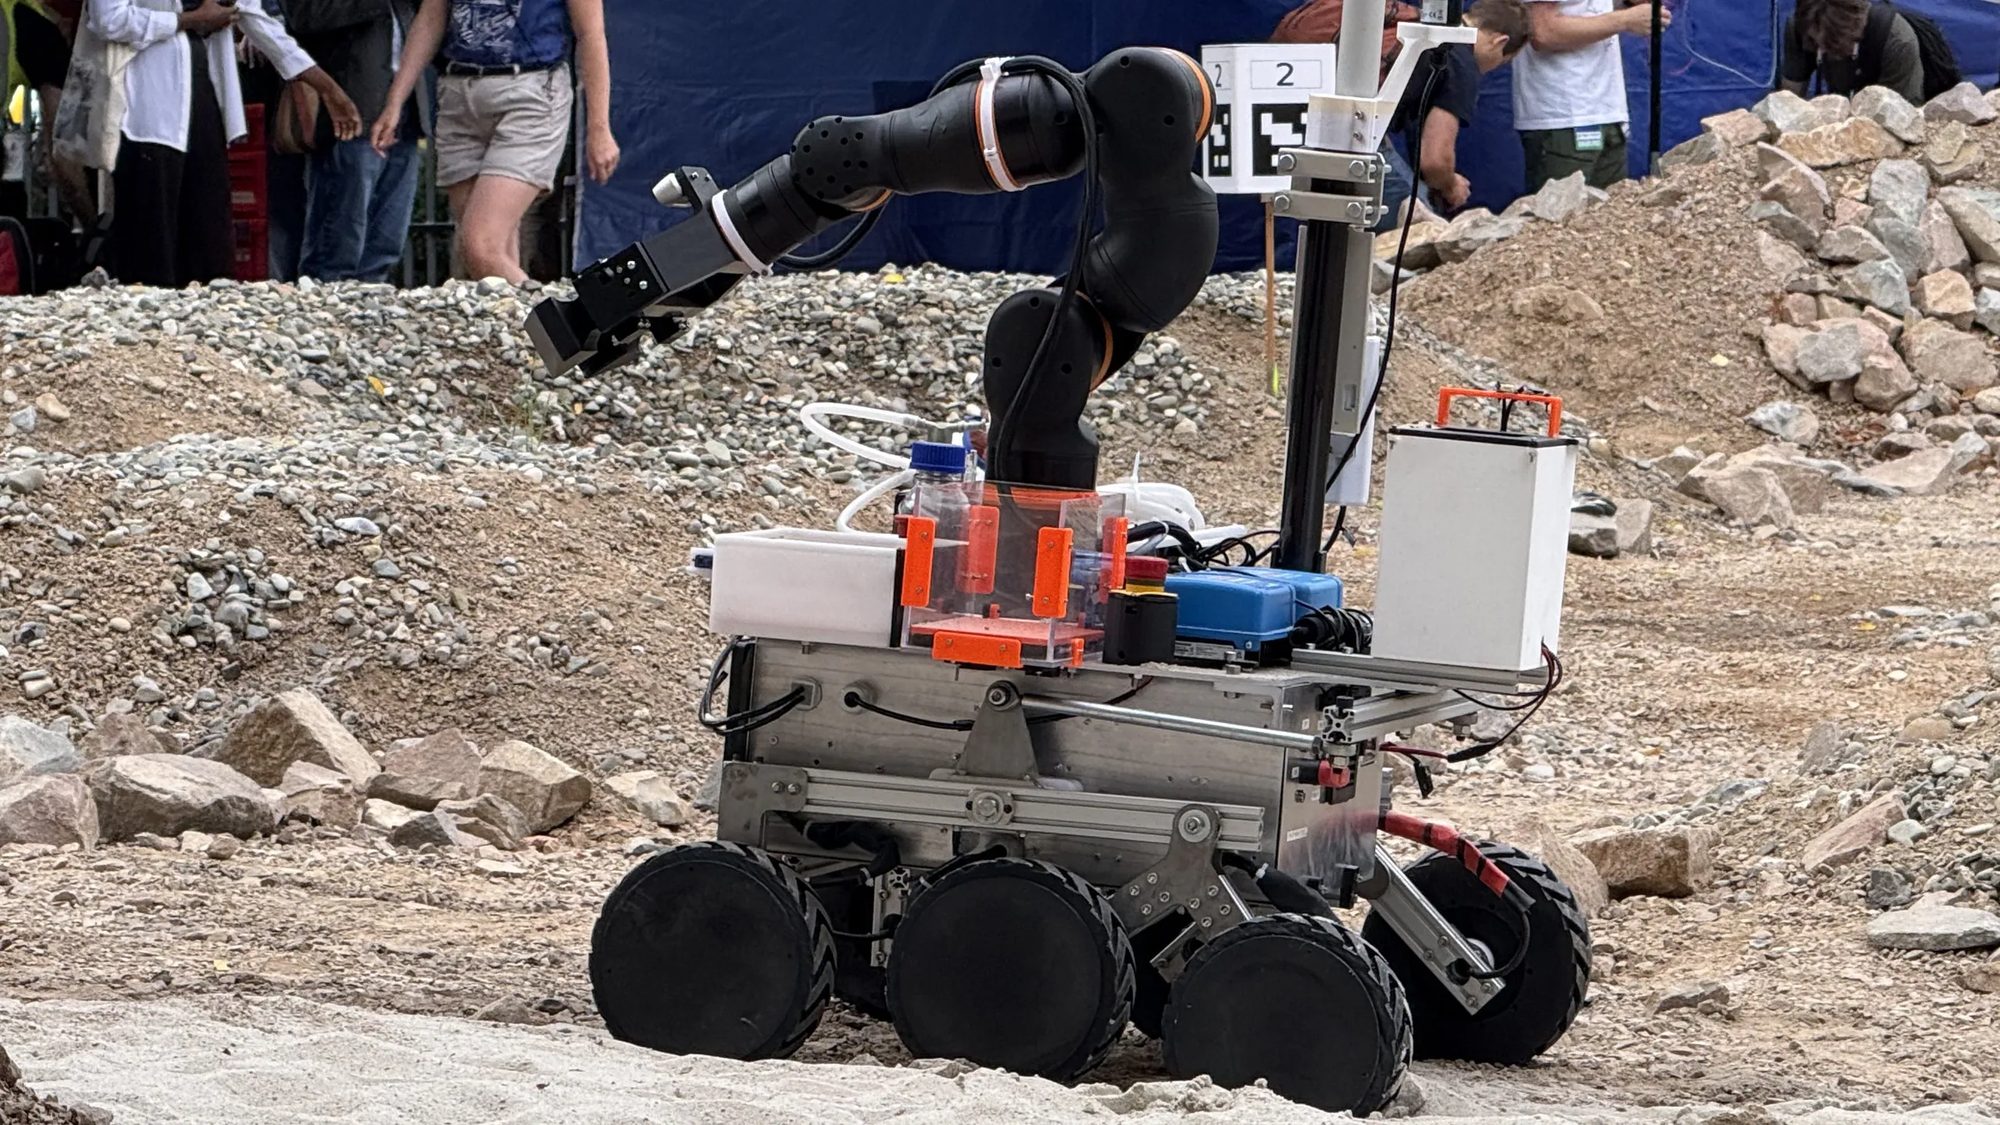
ERC 2026, Kraków
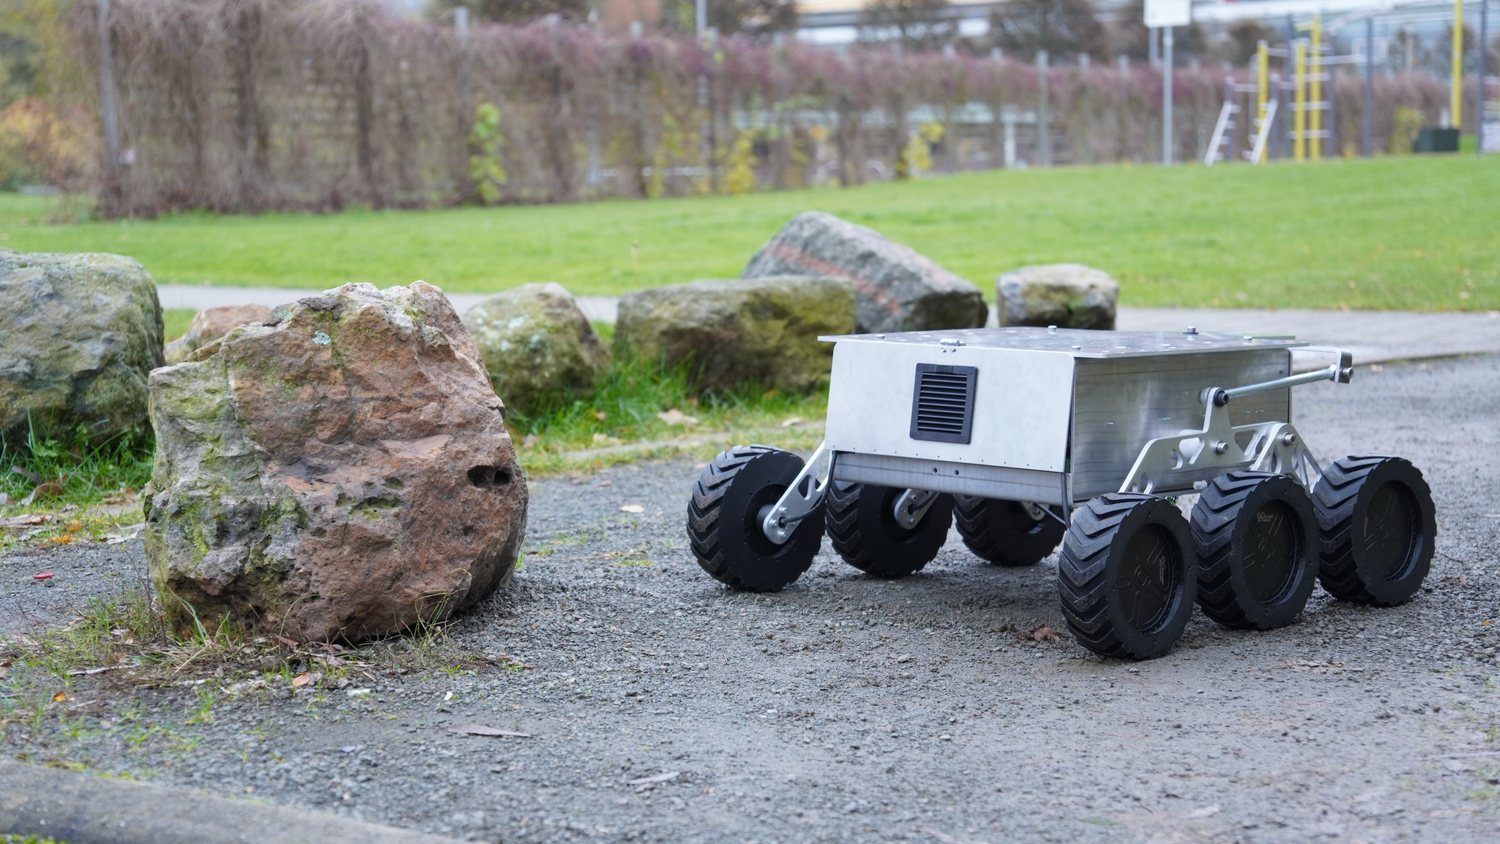
LEAP-One / built by the HSM Aries student team
000° / 360° · 0%
[01] Mobility
Six driven wheels.
Botwheel BLDC hub motors on ODrive S1 controllers, 180 mm of ground clearance, one 25.6 V bus.
[02] Suspension
Passive rocker-bogie.
Geometry keeps all six wheels in contact while the ground refuses to stay flat.
[03] Manipulation
A 6-DoF arm.
An Igus ReBeL arm flips switches on the maintenance panel and lifts sample containers.
[04] Science
A 530 mm auger.
Deep sampling at 300 mm and below, cached on board for the science task.
[05] Mentoring
KK's part.
Identity, the website, and reviews on manufacturability, suspension and the electronic bay. The engineering credit belongs to the students.
Scroll to rotate · Drag to nudge
Overview
LEAP-One is an exploration rover platform engineered to traverse Martian analogue terrains, collect sub-surface geological samples, and operate autonomously over telemetry-constrained radio links.
Challenge
Maintaining continuous ground contact across steep slopes, jagged boulders, and loose sand while carrying a heavy 6-DOF robotic manipulator and sensitive scientific assay sensors.
Approach
Implementation of a refined passive rocker-bogie suspension system with individual hub-motor drives, distributing chassis mass evenly and preventing wheel slip without heavy active hydraulics.
Architecture
- 01
Suspension: Passive rocker-bogie linkage distributing wheel ground pressure across obstacles twice wheel diameter.
- 02
Traction: 6 independently driven brushless hub actuators with planetary reduction and slip-ring rotation.
- 03
Scientific Manipulator: Multi-axis robotic arm with exchangeable end-effector for soil sample extraction and cache storage.
- 04
Sensor Mast: Stereo depth cameras, 3D LiDAR scanner, and high-gain antenna mast.
- 05
Autonomous Compute: Onboard NVIDIA Jetson edge compute executing local visual SLAM and obstacle cost-mapping.
Specifications
- Drive Configuration
- 6x6 Independent Hub Motors
- Suspension Architecture
- Passive Rocker-Bogie
- Scientific Payload
- Soil Extraction & Deep Cache Container
- Navigation Autonomy
- Local 3D LiDAR SLAM & Terrain Costmap
Stack
Rocker-Bogie Mechanics · Brushless DC Actuators · NVIDIA Jetson · Stereo Depth Sensing · Velodyne LiDAR · ROS 2 Navigation
Attribution
Designed and built by the HSM Aries student team; industry mentoring and subsystem guidance by KK Achari.